|
Hi, I am a first year PhD student at Örebro University in Machine Perception and Interaction lab in Sweden, advised by Amy Loutfi and Denis Kleyko. I am working on Curiosity driven Reinforcement Learning for Embodied AI. My research is supported by Wallenberg AI, Autonomous Systems and Software Program (WASP). I received my Masters Degree in Information Technology from University of Stuttgart in Germany. In my Master Thesis, I conducted research on multiple-human behaviour prediction using Vision Language Models under the supervision of Yuchen Liu, Luigi Palmieri, and Prof. Dr. Marco Aiello, in collaboration with Bosch Center for Artificial Intelligence. My research focuses on developing robust robot control policies for real-world scenarios, with an emphasis on humanoid whole-body control through end-to-end learning. I am also interested in exploration techniques for efficient learning in reinforcement learning. Email | GitHub | Google Scholar | LinkedIn | Blog |

|
|
Hi, I am a first year PhD student at Örebro University in Machine Perception and Interaction lab in Sweden, advised by Amy Loutfi and Denis Kleyko. I am working on Curiosity driven Reinforcement Learning for Embodied AI. My research is supported by Wallenberg AI, Autonomous Systems and Software Program (WASP). I received my Masters Degree in Information Technology from University of Stuttgart in Germany. In my Master Thesis, I conducted research on multiple-human behaviour prediction using Vision Language Models under the supervision of Yuchen Liu, Luigi Palmieri, and Prof. Dr. Marco Aiello, in collaboration with Bosch Center for Artificial Intelligence. My research focuses on developing robust robot control policies for real-world scenarios, with an emphasis on humanoid whole-body control through end-to-end learning. I am also interested in exploration techniques for efficient learning in reinforcement learning. Email | GitHub | Google Scholar | LinkedIn | Blog |
|
|
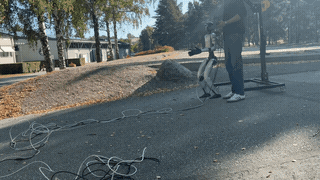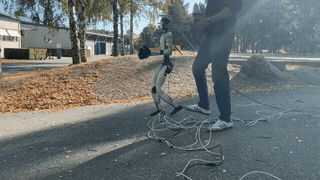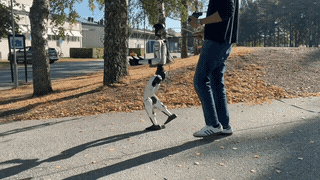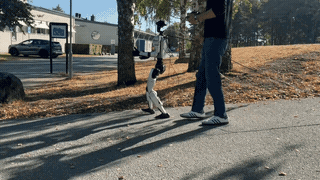 |
Utsav Panchal, Denis Kleyko, Unal Artan , Amy Loutfi ArXiv preprint , 2026 pdf | project-page | code |
 |
Utsav Panchal, Yuchen Liu, Luigi Palmieri, Ilche Georgievski , Marco Aiello IEEE CVF Winter Conference on Applications of Computer Vision (WACV) , 2026 pdf | project-page |
 |
Utsav Panchal, M.Sc. Thesis, University of Stuttgart & Bosch Research, 2025 thesis | slides | code | bibtex |
|
template adapted from this awesome website |